Sumin Lee
Computer Vision & Autonomous Driving Researcher
Teaching machines to see, and to drive.
Intelligent Robotics & Computer Vision Lab · Hanyang University
I’m a Master’s researcher at the Intelligent Robotics & Computer Vision Lab, Hanyang University, working on vision-centric autonomous driving.
My current research focuses on Gaussian Splatting for autonomous driving and Online Mapping, asking how modern 3D scene representations can reshape the next generation of perception and planning.
Demo
3D Gaussian SplattingNews
- 2026·09 accepted ReSMap got into NeurIPS 2026 🎉 Co-first author on online HD map construction with satellite priors
- 2025·06 award 3rd place at the Waymo Open Dataset Challenge: Vision-based End-to-End Driving (CVPR 2025)
- 2025·03 milestone Began MS at Hanyang University, Dept. of Automotive Engineering
Publications
ReSMap: Recasting Satellite Priors for Robust and Accurate Online HD Map Construction
Online HD Mapping · Satellite Priors
equal contribution · † corresponding author
Selected Projects
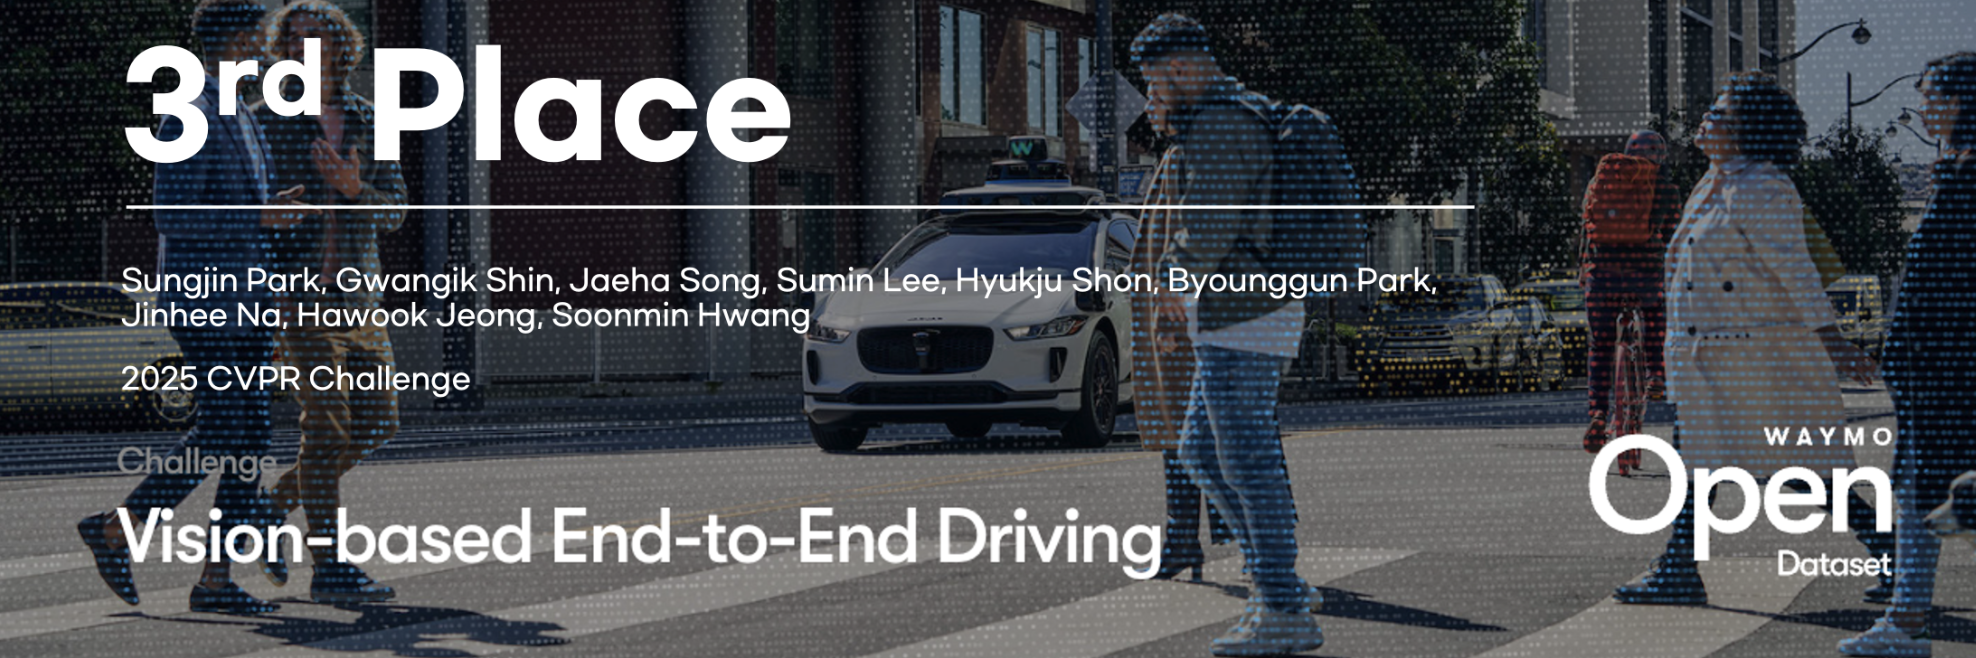 3rd Place
Swin-Trajectory
Vision-based End-to-End Driving · Waymo Open Dataset Challenge (CVPR 2025)
A minimalist transformer-based waypoint planner that takes a single front-facing camera and structured ego-vehicle history as input. A lightweight Swin Transformer backbone cross-attends to dynamic waypoint queries to efficiently regress future trajectories, competitive with much heavier multi-sensor baselines.
Deep thanks to my teammates, my supervisor, and RideFlux for technical support and collaboration.
 Top 3 / 30 · Solo Award
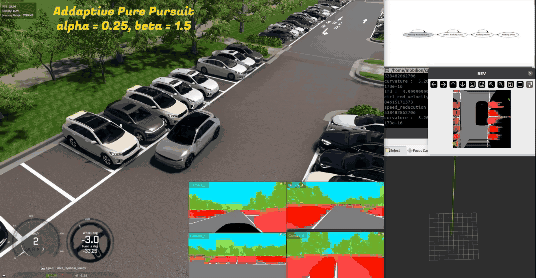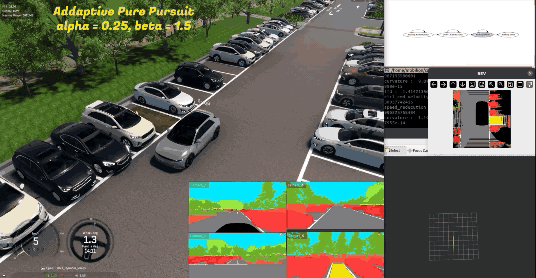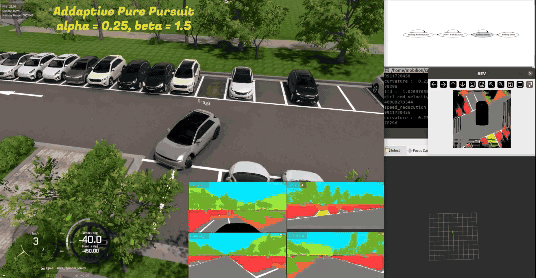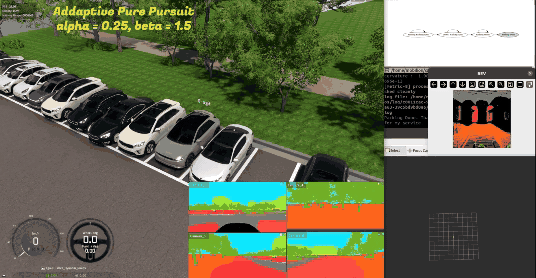
Autonomous Valet Parking System
Capstone Design Project · full-stack autonomy
End-to-end Perception → Planning → Control pipeline for a self-parking vehicle, built solo. Integrated BEV-based perception, motion planning, and an adaptive pure-pursuit controller into a single coherent system. The cornerstone of my academic path into autonomy.
Experience
-
2025·03 – Present
MS Researcher
Intelligent Robotics & Computer Vision Lab, Hanyang University
- Researching Gaussian Splatting for autonomous driving and Online Mapping
- Co-first-author paper accepted at NeurIPS 2026 (ReSMap)
-
2023·09 – 2025·02
Undergraduate Researcher
Intelligent Robotics & Computer Vision Lab, Hanyang University
- Started with path planning, expanded into multi-sensor perception (camera–LiDAR)
- Pivoted toward vision-centric end-to-end planning
Education
Inha University
Naval Architecture & Ocean Engineering → Mechanical Engineering (transferred)
Foundational engineering studies across two majors.
Hanyang University
BS · Dept. of Automotive Engineering
gpa 4.03 / 4.5
Joined IRCV Lab as an undergraduate researcher in Sep 2023.
Hanyang University
MS · Dept. of Automotive Engineering
gpa 4.33 / 4.5
Researching Gaussian Splatting & Online Mapping at IRCV Lab.
Stack
languages
frameworks
systems
Contact
Let's build the next frontier of autonomy together.
Open to research collaborations, internships and discussions on Gaussian Splatting, Online Mapping, and end-to-end driving.